Digital Twins & Simulation
Build models of vehicles, robots, and machines. Investigate operating conditions, optimize designs, and develop virtual testing workflows.
MECHATRONICS / DIGITAL TWINS / CONTROLS
I’m Khánh Nguyễn, a mechatronics engineer and founder of TwinDroid Inc. I help engineering teams understand complex machines, develop better controls, and make informed design decisions through simulation.
01 / HOW I CAN HELP
Through TwinDroid, I bring modeling, virtual testing, & controls together to help you create digital twins of your machines/robots/vehicles and evaluate their performance before building prototypes.
Build models of vehicles, robots, and machines. Investigate operating conditions, optimize designs, and develop virtual testing workflows.
Develop and evaluate robust & optimal control strategies for active suspension, steer by wire, and trajectory tracking—with the system’s physical behavior in mind.
Study ride comfort, handling, and durability loads. Automate analysis and transfer CAE simulation methodologies so your team can build on the work.
02 / SELECTED WORK & EXPERIMENTS
From full-vehicle simulation to robotics and software. Explore the models, methods, and working demonstrations.
Control development with vehicle models exceeding 500 degrees of freedom. Blue: active suspension; red: passive.
Trajectory and speed tracking using sliding mode control, PID, and torque vectoring.
iOS and Android development with Flutter, backed by AWS services and CI/CD.
Virtual analysis of handling, ride comfort, and durability loads using multibody simulation.
Challenging off-road and stair-climbing simulations in ADAMS/Car.
A Python implementation of model predictive control for vehicle maneuvers.
PID control of a six-wheel robot, developed in MATLAB.
Model-reduction methods for multibody systems, including suspension models.
Investigating uncontrollable and unobservable systems.
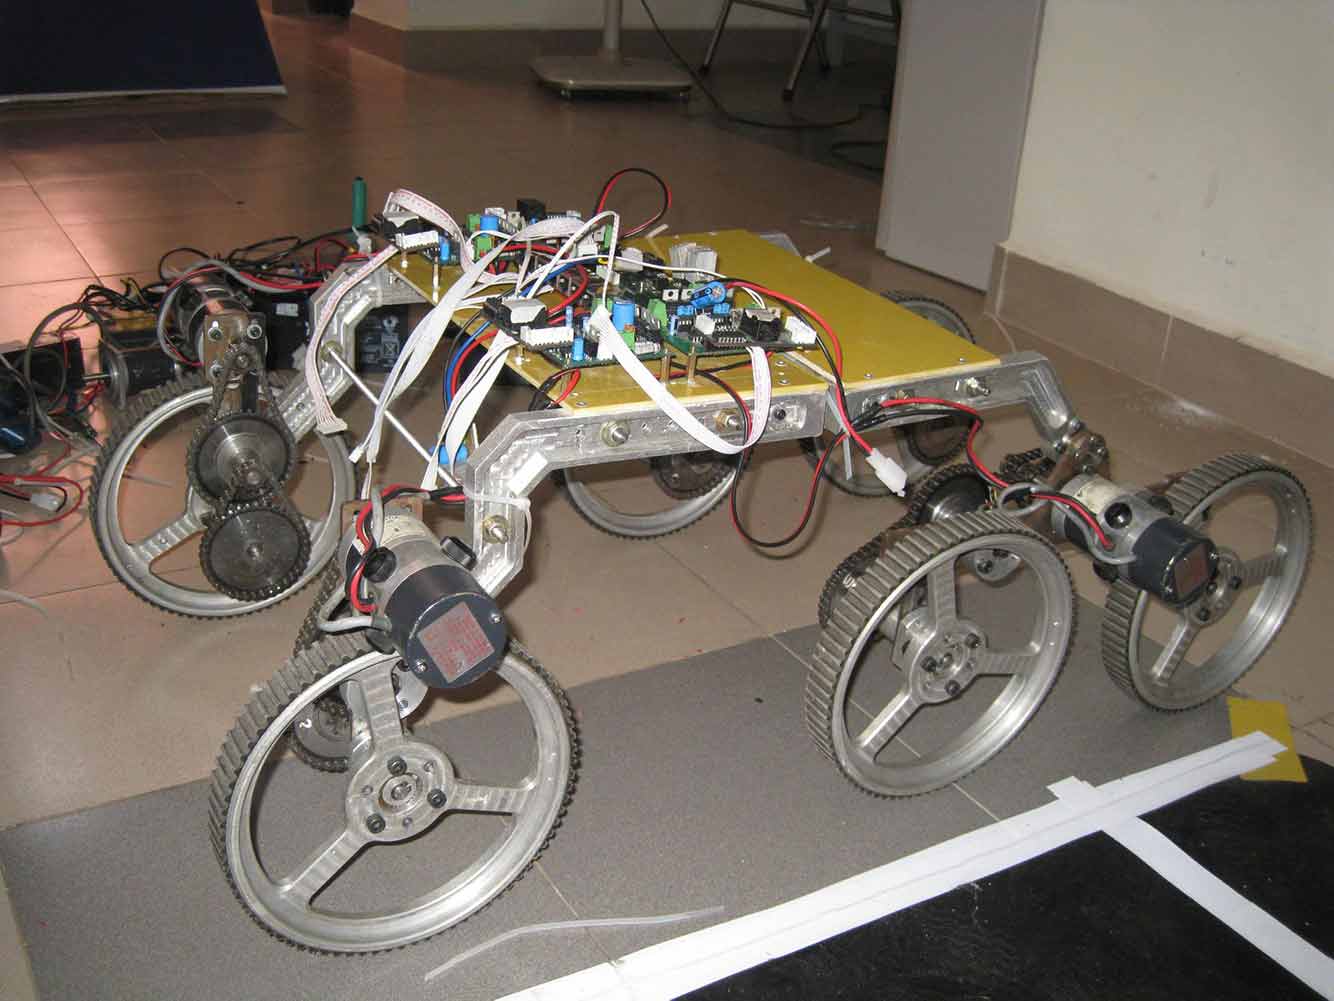
Programming a mobile robot for an all-terrain robotics competition.
Manipulator programming that turns names into controlled motion.
THE ENGINEER BEHIND THE WORK
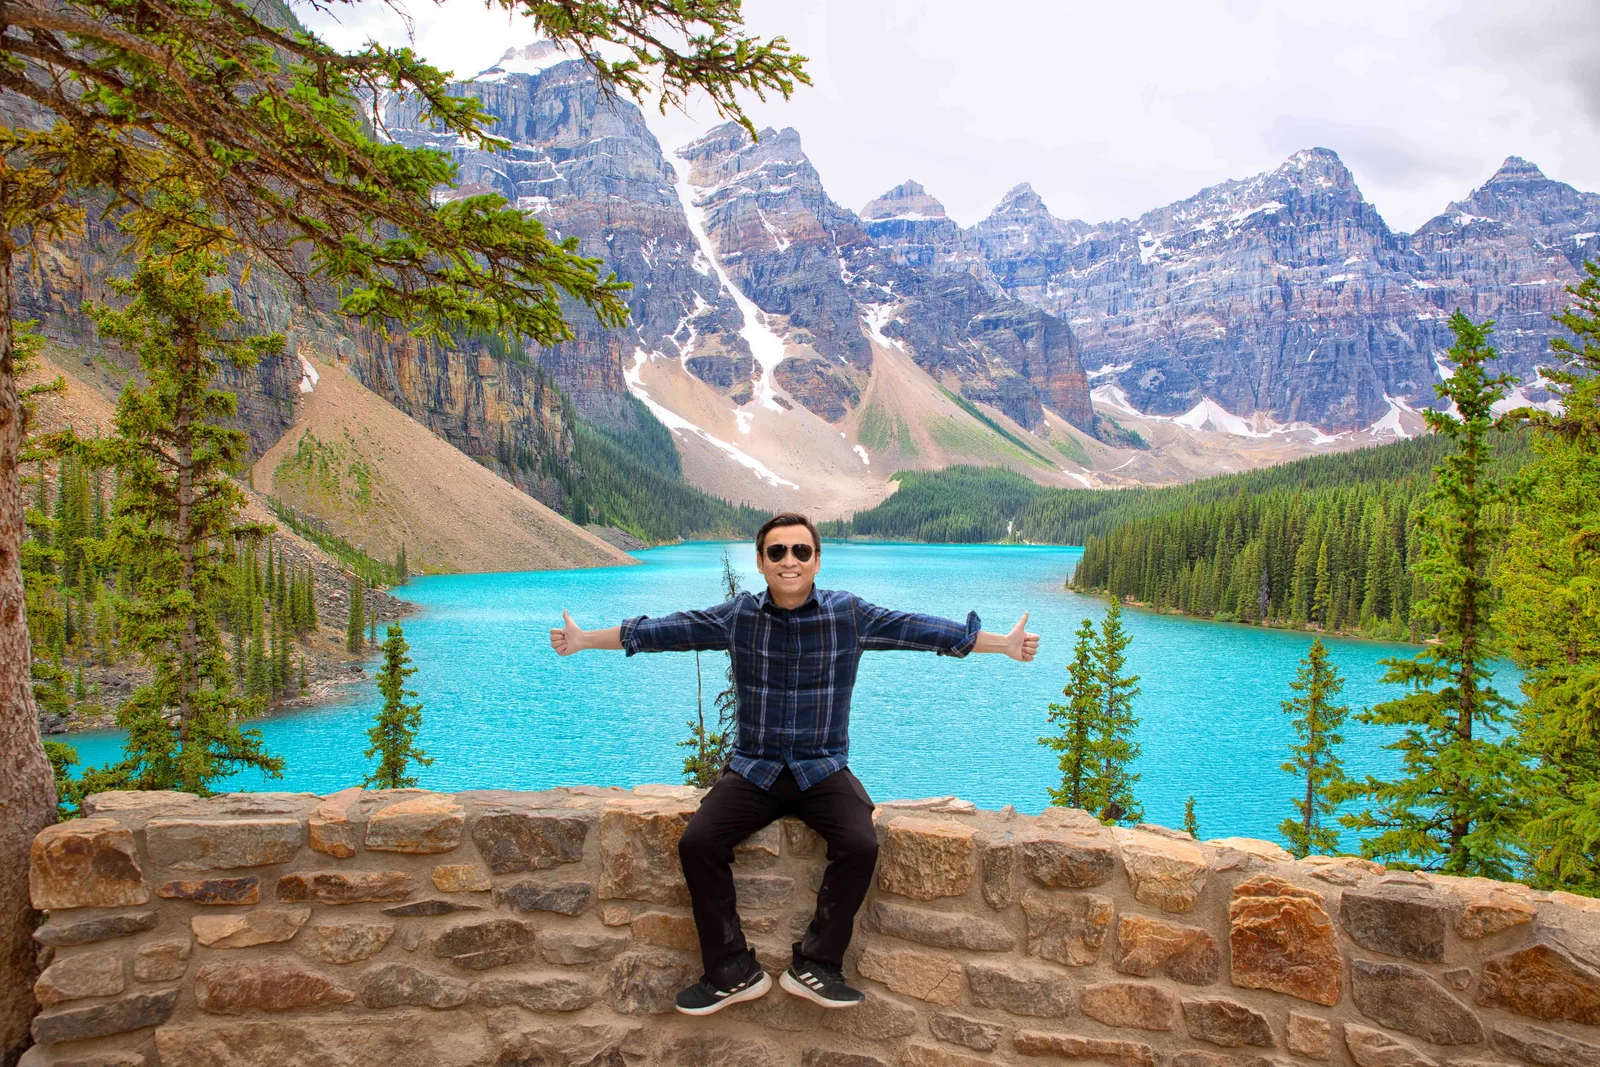
Mechatronics engineer.
Researcher. Builder. Founder.
MY WORKBENCH
03 / ABOUT ME
The most useful engineering model is one that helps you make a better decision. That idea connects my work in vehicle dynamics, advanced controls, and software development.
At Stellantis, I developed virtual road load data acquisition methods to study ride, handling, and durability through full-vehicle simulation. My work at Ford’s Research & Innovation Center has focused on active suspension, steering controls, and software-in-the-loop evaluation—bringing control algorithms and detailed vehicle models together.
I founded TwinDroid Inc. to bring that experience to teams building vehicles, robots, and machines. I can help translate a physical problem into a model, use simulation to compare approaches, and develop the controls and analysis tools needed to move the work forward.
My foundation is in mechatronics and applied mathematics, with a master’s degree from the University of Waterloo and the First Prize in Algebra at Vietnam’s National Mathematics Olympiad. Building mobile apps with Flutter and AWS has also taught me to think beyond the algorithm—to the people using the product and the systems that keep it running.
I bring curiosity, technical depth, and a hands-on approach. If you have a difficult dynamics or controls problem, I’d welcome a conversation.
Tell me what you’re building04 / BACKGROUND
Experience across automotive engineering, applied research, and entrepreneurship.
University of Waterloo, Waterloo, Canada
Training Program for Excellence Engineers (PFIEV)
Ho Chi Minh city University of Technology, Vietnam
INPG Grenoble Institute of Technology, France
US & Canada
Dearborn, MI, US
Ontario, Canada
Windsor, Ontario, Canada
05 / LET’S BUILD SOMETHING
A new machine. A difficult control problem. A simulation workflow that needs to go further. Tell me where you are and what you want to achieve.
Start a conversation